OpenZhenZhen AI 提示词画廊 · MiniMax H3 · video
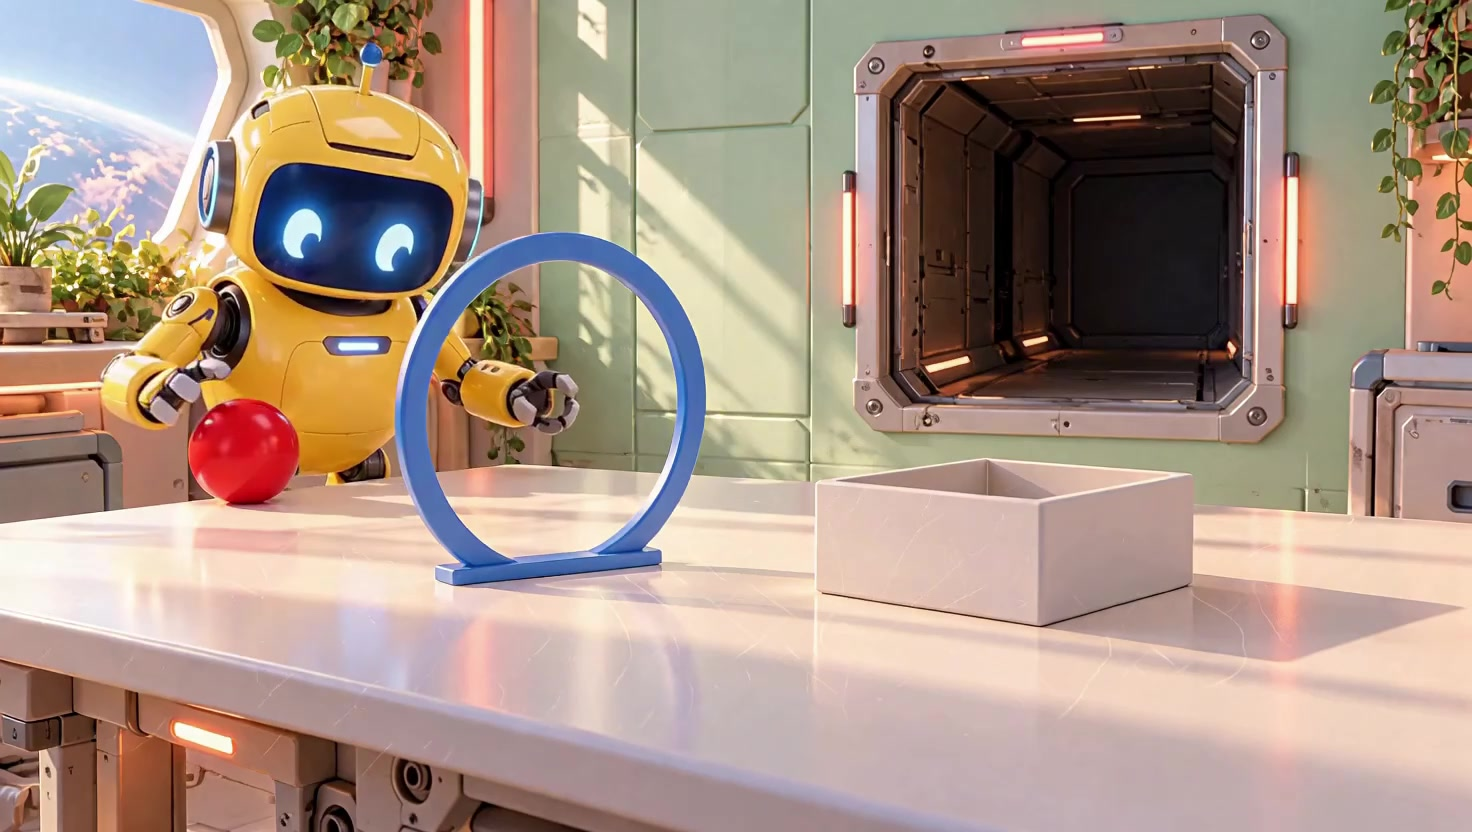
小机器人双手接住滚动红球
Little Robot Catching a Rolling Red Ball with Both Hands
8秒连续动作示例:小机器人双手接住滚动红球。
提示词 / Prompt
中文提示词
8秒连续镜头,精致3D动画风格。一个小型黄色双手机器人、一颗红球、一个台座、一个打开的方形墙洞和一个直立蓝环。参考图1定义唯一场景的构图和角色身份;参考图2仅为同一地点的环境参考;参考图3是图1中同一件主要道具的设计近景,不是第二件道具。将三图组合成一个连贯场景,不能做成三联画。只使用动作中明确规定的物体数量。机器人把唯一红球推过平坦桌面,收回推球的手,再用另一只夹爪在桌边之前接住同一颗仍在滚动的球。摄影机固定为中广角四分之三视角,使相关双手、道具、接触面与最终状态始终可见。以自然速度连续完整展示动作,不剪切、不转场、不插入其他画面、不增加表演者或魔法效果。遵守实体边界与正常物理支撑。尽快开始指定动作,结束状态短暂停留。无字幕、UI、水印或画面标签。适当而安静的室内环境声和自然接触声,无对白、无背景音乐。
English prompt
summary: [reference generation] One continuous 8-second shot in polished 3D animation style. One small yellow two-handed service robot, one red sphere, a pedestal, one open square wall hatch, one upright blue hoop. reference_roles: Picture 1 defines the SINGLE scene composition and character identity. Picture 2 is environment-only reference for that SAME location. Picture 3 is a close-up design reference for the SAME hero object visible in Picture 1, NOT a second object. Combine these references into one coherent scene, not three panels. Use only the object counts explicitly stated in the action. detailed_description: The robot pushes the one sphere across the flat tabletop, withdraws its pushing hand, then catches that same rolling sphere with the other gripper before the table edge. Camera: locked medium-wide three-quarter view keeping relevant hands, props, contact surfaces and end state visible. Show the entire action continuously at natural speed; no cuts, transitions, cutaways, extra performers or magical effects. Respect solid object boundaries and normal physical support. Start the requested action promptly and hold the final state briefly. No subtitles, UI, watermarks or on-screen labels. overall_soundscape: Quiet appropriate room ambience and natural contact sounds; no speech. non_diegetic_music: None.
主题与风格
探索更多图片和视频提示词 · 生成图片 · 生成视频 · 在 AI 画布中创作
相关作品
- 黏土宇航员左提箱右拾扳手再归位
10秒连续动作示例:黏土宇航员左提箱右拾扳手再归位。
- 刀鞘分别放地再拾起对准入鞘
10秒连续动作示例:刀鞘分别放地再拾起对准入鞘。
- 武士刀横竖转向换手后平放地板
10秒连续动作示例:武士刀横竖转向换手后平放地板。
- 女厨师盖锅平移再取下玻璃盖
10秒连续动作示例:女厨师盖锅平移再取下玻璃盖。
- 武士刀放地后握红柄重新入鞘
10秒连续动作示例:武士刀放地后握红柄重新入鞘。
- 蓝杯绕过木隔板再移入空托盘
10秒连续动作示例:蓝杯绕过木隔板再移入空托盘。